volume_object_model_3d_relative_to_plane🔗
Short description🔗
volume_object_model_3d_relative_to_plane — Calculate the volume of a 3D object model.
Signature🔗
volume_object_model_3d_relative_to_plane( object_model_3d ObjectModel3D, pose Plane, string Mode, string UseFaceOrientation, out number Volume )
Description🔗
volume_object_model_3d_relative_to_plane calculates the volume
under the faces of a 3D object model relative to a plane. The plane is
defined by the x-y plane of the pose given in Plane.
For ObjectModel3D, a triangulation or a list of polygons must be
available. With default settings, if the mesh is watertight and ordered, the
operator calculates the actual volume of the 3D object model.
To also cover cases where the mesh is not closed or the faces are not
ordered consistently, the calculation of the volume can be influenced
with the parameters Mode and UseFaceOrientation.
How the volume is calculated:
First, the operator calculates the volume of the prisms that are constructed by projecting each face onto the plane.
The individual volumes of the prisms can be positive or negative depending
on the orientation of the face (away or towards the plane) or the
location of the face (above or below the plane). This can be controlled
with the parameter UseFaceOrientation.
After that, the volumes of the prisms are added up depending on the
parameter Mode.
The volume returned in Volume is the absolute value of the
calculated sum.
How to set the parameters:
Mode can be set to the following options:
-
‘signed’ (default) The volumes above and below the plane are added.
-
‘unsigned’ The volume below the plane is subtracted from the volume above the plane.
-
‘positive’ Only faces above the plane are taken into account.
-
‘negative’ Only faces below the plane are taken into account.
UseFaceOrientation can be set to the following options:
-
‘true’ (default) Use the orientation of the faces relative to the plane. A face points away from the plane if the corner points are ordered clockwise when viewed from the plane. The volume under a face is considered positive if the orientation of the face is away from the plane. In contrast, it is considered negative if the orientation of the face is towards the plane.
-
‘false’ The volume under a face is considered positive if the face is located above the plane. In contrast, it is considered negative if the face is located below the plane.
For example, with the default combination (Mode: 'signed',
UseFaceOrientation: 'true'), you can approximate the
real volume of a closed object. In this case, the Plane is still
required, but does not change the resulting volume.
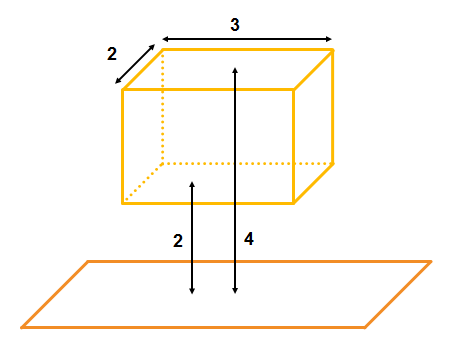
Example: (A) Mode: 'signed',
UseFaceOrientation: 'true': \(V = (2*3*4) + (-2*3*2) = 24-12 = 12\)
(B) Mode: 'signed',
UseFaceOrientation: 'false': \(V = (2*3*4) + (2*3*2) = 24+12 = 36\) (C) Mode: 'negative': \(V = 0\)
Attention🔗
The calculation of the volume might be numerically unstable in case of a large distance between the plane and the object (approx. distance > 10000 times the object diameter).
Execution information🔗
Execution information
-
Multithreading type: reentrant (runs in parallel with non-exclusive operators).
-
Multithreading scope: global (may be called from any thread).
-
Processed without parallelization.
Parameters🔗
ObjectModel3D (input_control) object_model_3d(-array) → (handle)
Handle of the 3D object model.
Plane (input_control) pose(-array) → (real / integer)
Pose of the plane.
Default: [0, 0, 0, 0, 0, 0, 0]
Mode (input_control) string(-array) → (string)
Method to combine volumes laying above and below the reference plane.
Default: 'signed'
List of values: 'negative', 'positive', 'signed', 'unsigned'
UseFaceOrientation (input_control) string(-array) → (string)
Decides whether the orientation of a face should affect the resulting sign of the underlying volume.
Default: 'true'
List of values: 'false', 'true'
Volume (output_control) number(-array) → (real)
Absolute value of the calculated volume.
Number of elements: Volume == ObjectModel3D
Example🔗
(HDevelop)
gen_box_object_model_3d ([0,0,0,0,0,0,0],3,2,1, ObjectModel3D)
convex_hull_object_model_3d (ObjectModel3D, ObjectModel3DConvexHull)
volume_object_model_3d_relative_to_plane (ObjectModel3DConvexHull,\
                                          [0,0,0,0,0,0,0], 'signed',\
                                          'true', Volume)
Result🔗
volume_object_model_3d_relative_to_plane returns 2 (H_MSG_TRUE) if all
parameters are correct. If necessary, an exception is raised.
Combinations with other operators🔗
Combinations
Possible predecessors
read_object_model_3d, xyz_to_object_model_3d, select_points_object_model_3d
Possible successors
project_object_model_3d, object_model_3d_to_xyz, select_object_model_3d
See also
Module🔗
3D Metrology