3D box🔗
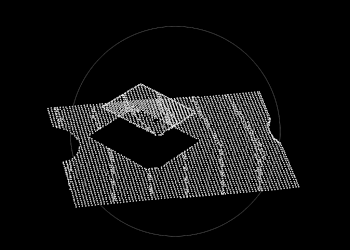
As its name suggests, the box finder can be used to locate box-shaped objects in 3D data.
Thereby, no model of the object is needed as an input for the operator find_box_3d, but only the dimensions of the boxes to be found.
As a result, you can retrieve the pose of a gripping point, which can be especially useful in the case of a bin picking application.
 |
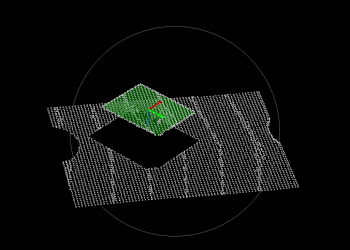 |
Figure 1.
3D input data (scene)
Found instance, including a gripping point