Deformable surface-based matching🔗
Deformable surface-based 3D matching allows to find 3D objects in 3D scenes even if the 3D objects are deformed to a certain degree.
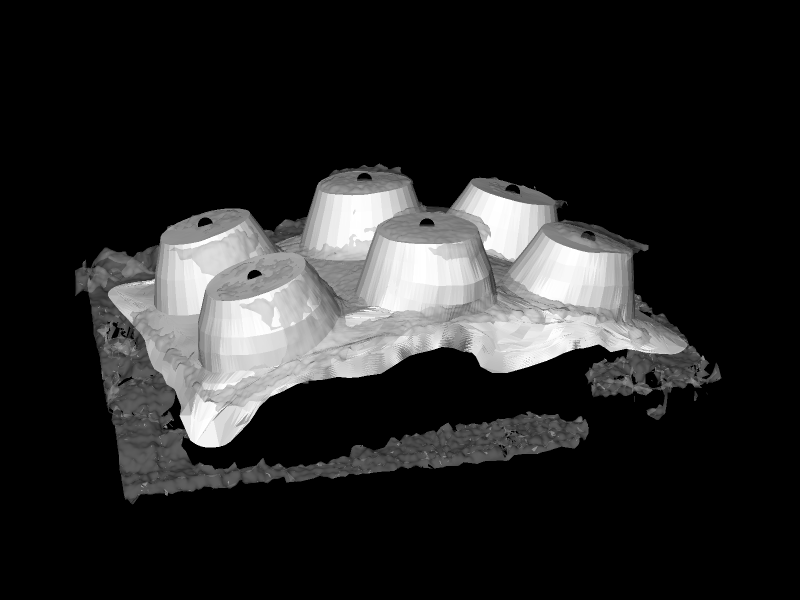
For the 3D pose estimation with deformable surface-based 3D matching, a deformable surface model is generated from a 3D object model that was obtained either from a 3D computer aided design (CAD) model, from a 3D reconstruction approach, for example, stereo vision or sheet of light, or directly by a 3D sensor.
The deformable surface model consists of a set of 3D points and the points’ normal vectors. That is, the corresponding information must be provided (at least implicitly) by the 3D object model.
In contrast to the shape-based 3D matching, the instances of the object are not located in images but in a 3D scene, i.e., in a set of 3D points that is provided as another 3D object model and which can be obtained by one of the above mentioned approaches or sensors.