3D transformations and poses🔗
3D coordinates🔗
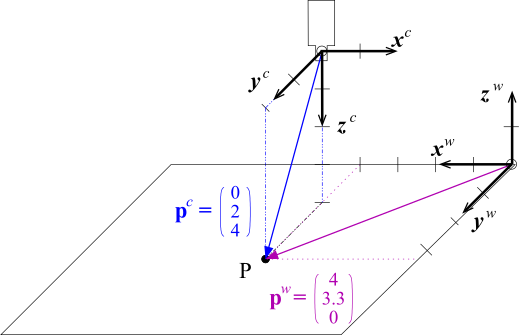
The position of a 3D point \(P\) is described by its three coordinates \((x^p, y^p, z^p)\). The coordinates can also be interpreted as a 3D vector (indicated by a bold-face lower-case letter). The coordinate system in which the point coordinates are given is indicated to the upper right of a vector or coordinate. For example, the coordinates of the point \(P\) in the camera coordinate system (denoted by the letter \(c\)) and in the world coordinate system (denoted by the letter \(w\)) would be written as:
Camera coordinates: \((x^c, y^c, z^c)\)
World coordinates: \((x^w, y^w, z^w)\)
Figure 1 depicts an example point lying in a plane where measurements are to be performed and its coordinates in the camera and world coordinate system, respectively.